Loading…
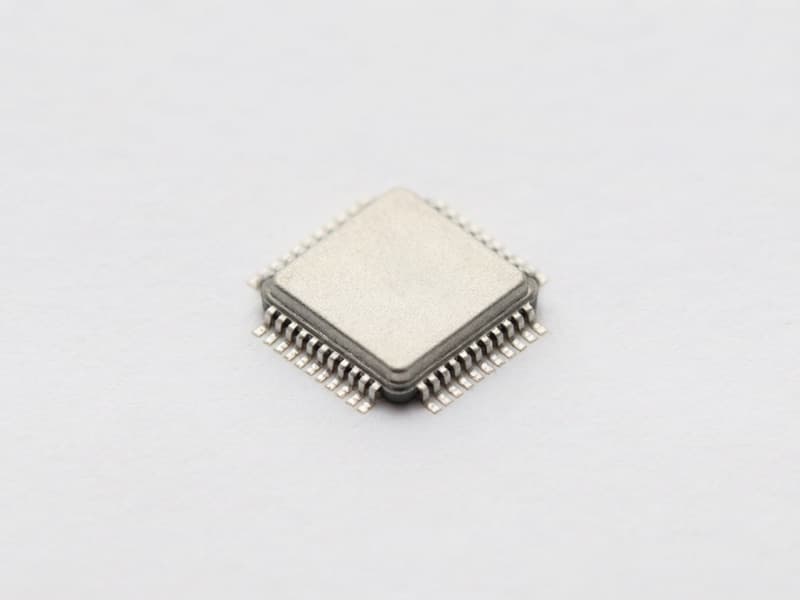
QFN-24 · MPU-6050
NRNDMotion Sensors (IMU)
MPU-6050
TDK InvenSense · QFN-24 · Motion Sensors (IMU)
Price on Request
Get a competitive quote within 24 hours. Volume discounts available. Shenzhen stock ships in 1-2 business days.
Overview
The MPU-6050 is TDK InvenSense's groundbreaking 6-axis motion tracking device, combining a 3-axis MEMS gyroscope and 3-axis MEMS accelerometer on a single 4×4×0.9 mm QFN-24 die with an integrated Digital Motion Processor (DMP). Released in 2010, it was the first consumer 6-axis IMU small and cheap enough for hobbyist drones, wearables and balance robots, and it remains the reference part for those applications today — despite its NRND (Not Recommended for New Designs) status.
Sensor specs: gyroscope full-scale range selectable ±250, ±500, ±1000, ±2000 °/s; accelerometer range ±2, ±4, ±8, ±16 g; both with 16-bit ADC output. Gyro noise density is 0.005 °/s/√Hz, accelerometer 200 µg/√Hz. Sample rates up to 8 kHz for gyro, 1 kHz for accel. I²C interface at 400 kHz (or SPI at 20 MHz on the MPU-6000 variant).
The DMP is a hardware-accelerated sensor fusion engine that runs a quaternion-based Kalman filter at 200 Hz, combining gyro and accel data to produce drift-free orientation output. This offloads significant computation from the host MCU and gives you stable pitch/roll/yaw without writing your own filter.
Operating supply is 2.375-3.46 V (VDD) with a separate 1.8-3.3 V I/O rail (VLOGIC). Active current is 3.9 mA with all sensors and DMP running; low-power accel-only mode draws 450 µA.
Because MPU-6050 is NRND, InvenSense recommends MPU-6500 (SPI + I²C, 6-axis), MPU-9250 (9-axis with magnetometer), or ICM-20602 (higher-performance 6-axis) for new designs. However, MPU-6050 remains widely available and heavily documented in Arduino, Raspberry Pi and open-source drone communities.
Our Shenzhen stock: QFN-24 MPU-6050, MOQ 500 pcs on tape or 50 pcs loose.
Key Features
- 6-axis MEMS IMU: 3-axis gyro (±2000 °/s) + 3-axis accel (±16 g)
- Integrated DMP runs sensor fusion at 200 Hz
- 16-bit ADC output on all channels
- I²C at 400 kHz, tiny 4×4 mm QFN-24
Typical Applications
- Multirotor drone flight controllers (KK2, MultiWii, early APM)
- Self-balancing robots and Segway-style platforms
- Wearable motion tracking and gesture recognition
- Sports telemetry (racket swings, golf clubs, cycling power)
- VR controllers and 3D mouse devices
Specifications
- Axes
- 6 (3 gyro + 3 accel)
- Gyro Range
- ±250 to ±2000 °/s
- Accel Range
- ±2 to ±16 g
- ADC Resolution
- 16 bit
- Interface
- I2C (400kHz)
- Supply Voltage
- 2.375 to 3.46 V
- Operating Temperature
- -40 to 85 °C
- Mounting Type
- Surface Mount
- RoHS
- Compliant
Procurement Tips
For new designs, migrate to ICM-20602 (higher performance, Active status, same QFN-24 footprint) or BMI160 (Bosch, lower cost, similar features). Both are available in the same footprint for drop-in replacement.
Frequently Asked Questions
Is MPU-6050 still recommended for new designs?
No — InvenSense/TDK marked it NRND (Not Recommended for New Designs) around 2018. It remains available and is heavily documented, but for new production use ICM-20602, MPU-6500 or BMI160 (Bosch) instead. Choose MPU-6050 only for hobbyist projects leveraging existing open-source code.
What is the DMP and do I need it?
Digital Motion Processor — an on-chip microcontroller that runs sensor fusion firmware. It outputs stable quaternions at 100-200 Hz without loading your main MCU. If you're building a drone or balance robot, use the DMP. For simple tilt detection or step counting, read raw gyro/accel registers directly and filter in software.
MPU-6050 vs MPU-9250 — what's the difference?
MPU-9250 adds a 3-axis magnetometer (AK8963 die co-packaged), has lower gyro noise (0.004 vs 0.005 °/s/√Hz), higher sample rates, and supports SPI at 20 MHz. Package is slightly larger QFN-24 3×3 mm vs 4×4 mm. MPU-9250 is Active status; MPU-6050 is NRND.
What I²C address does it use?
AD0 pin selects between 0x68 (AD0 low) and 0x69 (AD0 high). This lets you connect two IMUs on the same bus.
How do I calibrate the MPU-6050?
Gyro: place the sensor perfectly still on a flat surface, read 1000 samples, average — that's the zero-rate offset to subtract. Accel: collect readings in 6 orientations (±X, ±Y, ±Z up), solve for 3-axis offset and scale matrix. Libraries like MPU6050_calibration.ino automate this.
MOQ and lead time?
MOQ 500 pcs on tape for QFN-24, or 50 pcs loose. TDK authorized channel is limited due to NRND status; Shenzhen broker stock 1-3 days but verify authenticity.
Alternatives & Equivalents
View full cross-reference table →Need MPU-6050 pricing and availability?
Submit an RFQ — we reply within 24 hours with stock, pricing, lead time and packaging options.
Request a Quote →